The area that a Model is run for, with Fuel, Slope, and Aspect grids.
More...
#include <Environment.h>
|
| std::optional< Coordinates > | findCoordinates (const Point &point, bool flipped) const |
| | Determine Coordinates in the grid for the Point.
|
| |
| constexpr string_view | proj4 () const |
| | UTM projection that this uses.
|
| |
|
constexpr Idx | height () const |
| |
|
constexpr Idx | width () const |
| |
| constexpr MathSize | cellSize () const |
| | Cell width and height (m)
|
| |
| constexpr ElevationSize | elevation () const |
| | Elevation of the origin Point.
|
| |
|
Cell | cell (const XYIdx &xy) const |
| |
|
Cell | offset (const Event &event, const Idx x, const Idx y) const |
| |
| shared_ptr< ProbabilityMap > | makeProbabilityMap (DurationSize time, DurationSize start_time, int min_value, int low_max, int med_max, int max_value, const shared_ptr< Perimeter > perimeter) const |
| | Make a ProbabilityMap that covers this Environment.
|
| |
| template<class Other > |
| GridMap< Other > | makeMap (const Other nodata) const |
| | Create a GridMap<Other> covering this Environment.
|
| |
|
const BurnedData & | unburnable () const |
| |
|
void | saveToFile (const string_view output_directory) const |
| |
|
MathSize | to_hectares (const size_t num_cells) const |
| |
|
|
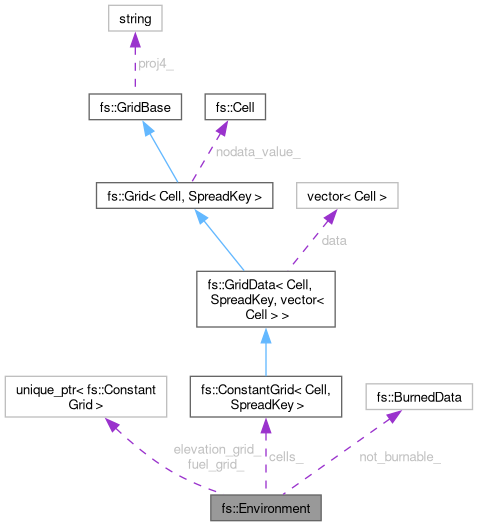
unique_ptr< FuelGrid > | fuel_grid_ {} |
| | Fuel grid (if saving simulation area)
|
| |
|
unique_ptr< ElevationGrid > | elevation_grid_ {} |
| | Elevation grid (if saving simulation area)
|
| |
|
CellGrid | cells_ {} |
| | Cells representing Environment.
|
| |
|
BurnedData | not_burnable_ {} |
| | Cells that are not burnable.
|
| |
|
ElevationSize | elevation_ {INVALID_ELEVATION} |
| | Elevation at StartPoint.
|
| |
The area that a Model is run for, with Fuel, Slope, and Aspect grids.
◆ Environment() [1/2]
| fs::Environment::Environment |
( |
unique_ptr< FuelGrid > | fuel_grid, |
|
|
unique_ptr< ElevationGrid > | elevation_grid, |
|
|
CellGrid && | cells, |
|
|
const ElevationSize | elevation ) |
|
protectednoexcept |
Construct from cells and elevation.
- Parameters
-
◆ Environment() [2/2]
Load from rasters.
- Parameters
-
| fuel | Fuel raster |
| elevation | Elevation raster |
◆ cellSize()
| MathSize fs::Environment::cellSize |
( |
| ) |
const |
|
inlinenodiscardconstexpr |
Cell width and height (m)
- Returns
- Cell width and height (m)
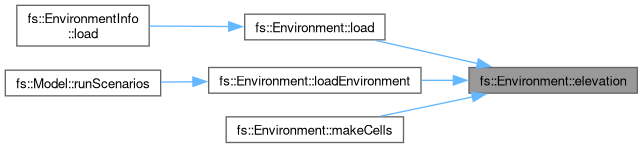
◆ elevation()
| ElevationSize fs::Environment::elevation |
( |
| ) |
const |
|
inlinenodiscardconstexpr |
Elevation of the origin Point.
- Returns
- Elevation of the origin Point
◆ findCoordinates()
| std::optional< Coordinates > fs::Environment::findCoordinates |
( |
const Point & | point, |
|
|
bool | flipped ) const |
|
nodiscard |
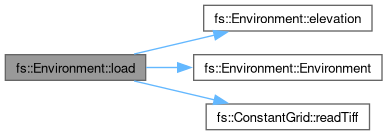
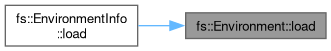
◆ load()
| Environment fs::Environment::load |
( |
const Point & | point, |
|
|
const string_view | in_fuel, |
|
|
const string_view | in_elevation ) |
|
staticnodiscard |
Load from rasters.
- Parameters
-
| point | Origin point |
| in_fuel | Fuel raster |
| in_elevation | Elevation raster |
- Returns
- Environment
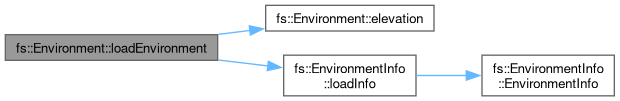
◆ loadEnvironment()
| Environment fs::Environment::loadEnvironment |
( |
const string_view | path, |
|
|
const Point & | point, |
|
|
const LazyPath & | perimeter, |
|
|
YearSize | year ) |
|
staticnodiscard |
Load from rasters in folder that have same projection as Perimeter.
- Parameters
-
| path | Folder to read rasters from |
| point | Origin point |
| perimeter | Perimeter to use projection from |
| year | Year to look for rasters for if available |
- Returns
- Environment
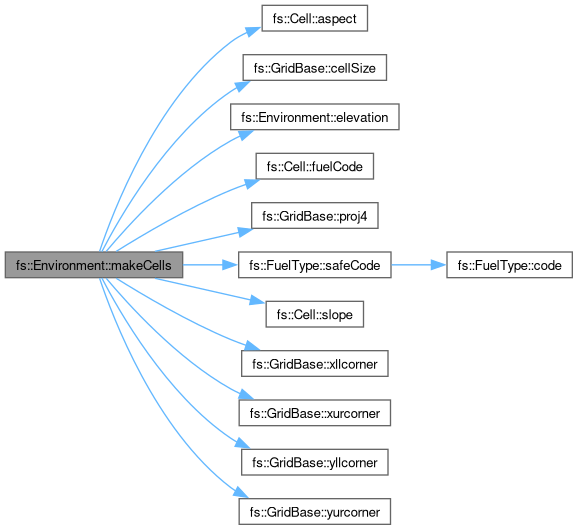
◆ makeCells()
Combine rasters into CellGrid.
- Parameters
-
| elevation | Elevation raster |
- Returns
◆ makeMap()
template<class Other >
| GridMap< Other > fs::Environment::makeMap |
( |
const Other | nodata | ) |
const |
|
inlinenodiscard |
Create a GridMap<Other> covering this Environment.
- Template Parameters
-
- Parameters
-
| nodata | Value that represents no data |
- Returns
- GridMap<Other> covering this Environment
◆ makeProbabilityMap()
| shared_ptr< ProbabilityMap > fs::Environment::makeProbabilityMap |
( |
DurationSize | time, |
|
|
DurationSize | start_time, |
|
|
int | min_value, |
|
|
int | low_max, |
|
|
int | med_max, |
|
|
int | max_value, |
|
|
const shared_ptr< Perimeter > | perimeter ) const |
|
nodiscard |
Make a ProbabilityMap that covers this Environment.
- Parameters
-
| time | Time in simulation this ProbabilityMap represents |
| start_time | Start time of simulation |
| min_value | Lower bound of 'low' intensity range |
| low_max | Upper bound of 'low' intensity range |
| med_max | Upper bound of 'moderate' intensity range |
| max_value | Upper bound of 'high' intensity range |
- Returns
- ProbabilityMap with the same extent as this
◆ proj4()
| string_view fs::Environment::proj4 |
( |
| ) |
const |
|
inlinenodiscardconstexpr |
UTM projection that this uses.
- Returns
- UTM projection that this uses
The documentation for this class was generated from the following files:






 1.12.0